Productbeschrijving
60mm DC SERVO MOTOR WITH BRAKE
Specificatie:
| General Specification | |
| (Item) | (Specification) |
| Winding type | Star |
| Hall effect angle | 120 120 degree electrical angle |
| Shaft run out | 0.571mm |
| Radial play | 0.02mm@450g |
| End play | 0.08mm@450g |
| Max.radial force | 115N @20mm form the flange |
| Max.axial force | 45N |
| Insulation class | Class B |
| Dielectric strength | 500VDC for 1 minute |
| Insulation resistance | 100MΩ Min.,500VDC |
| Electrical Specification | |||||
| Specification | Eenheid | JK60BLS01 | JK60BLS02 | JK60BLS03 | JK60BLS04 |
| Number Of Phase | Phase | 3 | |||
| Number Of Poles | Poles | 8 | |||
| Rated Voltage | VDC | 48 | |||
| Rated Speed | Rpm | 3000 | |||
| Rated Torque | N.m | 0.3 | 0.6 | 0.9 | 1.2 |
| Rated Current | Amps | 2.8 | 5.2 | 7.5 | 9.5 |
| Rated Power | W | 94 | 188 | 283 | 377 |
| Peak Torque | N.m | 0.9 | 1.8 | 2.7 | 3.6 |
| Peak Current | Amps | 8.4 | 15.6 | 22.5 | 28.5 |
| Back E.M.F | V/Krpm | 12.1 | 12.6 | 12.4 | 13.3 |
| Torque Constant | N.m/A | 0.116 | 0.12 | 0.118 | 0.127 |
| Rotor Inertia | Kg.c | 0.24 | 0.48 | 0.72 | 0.96 |
| Body Length | mm | 78 | 99 | 120 | 141 |
| Weight | Kg | 0.85 | 1.25 | 1.65 | 2.05 |
| Sensor | /Honeywell | ||||
| Insulation Class | B | ||||
| Degree of Protection | IP30 | ||||
| Storage Temperature | -25~+70ºC | ||||
| Operating Temperature | -15~+50ºC | ||||
| Working Humidity | 85% RH | ||||
Drawing:
Company Profile:
HangZhou CHINAMFG CO.,LTD (HangZhou Jingkong Motor&Electric Appliance Co.,Ltd)is an ISO9001 Professional
manufacturer. Was established in 2011 year. We are a professional manufacturer in HangZhou city, China. Production Capacity
exceeds more than 1million motors per year.
Our Company offers 3 major series of products: Hybrid Stepper motors, Brushless Dc motor and Dc Brush motor.
We are always continues develop new type models.We are also have several joint venture companies who specialized in the
production of AC servo motor, PM stepper motors, Spindlemotor and Motor drivers. We export our motors to more than 30
countries Such as United States, Germany, Russia, Turkey, Brazil and so on.
Jkongmotor sold to major manufacturing Companies for Industry of automation, medical and health care equipment,
3d printermachines, packing devices, Information Technology, household appliance products. We have an Engineering team
with many years of experience in application Engineering, design Engineering with the latest advances equipment. Our
Engineering Staff provides the finest quality product with service after the product is delivered to our Customers.
| Sollicitatie: | Universal, Industrial, Household Appliances, Car, Power Tools |
|---|---|
| Operating Speed: | High Speed |
| Functie: | Control |
| Casing Protection: | Closed Type |
| Number of Poles: | 8 |
| Structure and Working Principle: | Brushless |
| Voorbeelden: |
US$ 28.5/Piece
1 stuk (minimale bestelling) | |
|---|
| Aanpassing: |
Beschikbaar
| Aanvraag op maat |
|---|
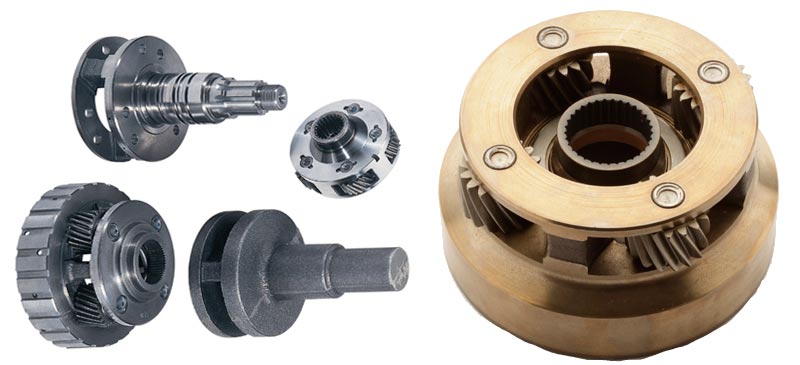
How do you calculate the gear ratio involving sun, planet, and ring gears?
The gear ratio in a planetary gear system can be calculated by considering the number of teeth on the sun gear, planet gears, and ring gear. The gear ratio determines the relationship between the input speed and the output speed of the system. Here’s how you can calculate the gear ratio:
- Step 1: Count the Teeth:
Count the number of teeth on the sun gear (S), the planet gears (P), and the ring gear (R). These numbers represent the respective gear’s tooth count.
- Step 2: Determine the Gear Arrangement:
Identify the gear arrangement. In a simple planetary gear system, the sun gear is at the center, surrounded by planet gears, and enclosed by the ring gear.
- Step 3: Calculate the Gear Ratio:
The gear ratio (GR) can be determined using the formula:
GR = (R + P) / S
Where:
- R represents the number of teeth on the ring gear
- P represents the number of teeth on the planet gears (assuming they have the same number of teeth)
- S represents the number of teeth on the sun gear
The resulting gear ratio represents the speed relationship between the input and output of the planetary gear system. A gear ratio greater than 1 indicates a speed reduction, while a gear ratio less than 1 indicates a speed increase.
It’s important to note that in more complex planetary gear systems, where there are multiple sets of planet gears or additional gears, the calculation of the gear ratio may involve considering multiple gear stages and their respective tooth counts.
In summary, to calculate the gear ratio involving sun, planet, and ring gears, you need to count the teeth on each gear and use the formula (R + P) / S, where R is the number of teeth on the ring gear, P is the number of teeth on the planet gears, and S is the number of teeth on the sun gear. This calculation provides the gear ratio that defines the speed relationship between the input and output of the planetary gear system.
Hoe gaan planetaire tandwieloverbrengingen om met variaties in de tandvertanding tijdens gebruik?
Planetaire tandwieloverbrengingen zijn ontworpen om variaties in de tandvertanding tijdens bedrijf op te vangen, waardoor een soepele en betrouwbare werking wordt gegarandeerd. Laten we eens bekijken hoe planetaire tandwieloverbrengingen deze variaties aanpakken:
- Tolerantie voor uitlijningsfouten:
Planetaire tandwieloverbrengingen zijn ontworpen met een zekere tolerantie voor uitlijningsafwijkingen. Dit betekent dat kleine variaties in de tandvertanding als gevolg van fabricagetoleranties, montage of bedrijfsomstandigheden worden opgevangen zonder dat dit een significante impact heeft op het tandwielsysteem. De tandwielen zijn zorgvuldig ontworpen met de juiste profielen, spelingen en backlash om een zekere mate van uitlijningsafwijking mogelijk te maken en tegelijkertijd een goede werking te garanderen.
- Belastingverdeling:
De opstelling van meerdere planeetwielen in een planetair tandwielstelsel zorgt ervoor dat de belasting over meerdere tandwielen wordt verdeeld. Elk planeetwiel deelt de belasting met de aangrenzende tandwielen, waardoor de spanning op individuele tanden wordt verminderd en een gelijkmatige tandgreep wordt bevorderd. Deze mogelijkheid tot lastverdeling minimaliseert plaatselijke slijtage, geluid en trillingen, wat resulteert in een soepelere en efficiëntere werking.
- Flexibele montage en ondersteuning:
Planetaire tandwieloverbrengingen worden vaak gemonteerd op flexibele ondersteuningsconstructies, zoals lagers of flexibele koppelingen. Deze componenten helpen kleine variaties in de tandvertanding tijdens bedrijf op te vangen en te compenseren. De flexibele montage- en ondersteuningssystemen bieden een zekere mate van flexibiliteit en aanpassingsvermogen, waardoor de tandwielen zichzelf kunnen afstellen en een goed tandcontact behouden onder wisselende bedrijfsomstandigheden.
- Smering en koeling:
Goede smering en koeling spelen een cruciale rol bij het beheersen van variaties in de tandvertanding. Smeermiddelen verminderen wrijving en slijtage tussen de tandwielen, waardoor een soepele werking wordt gegarandeerd en de impact van variaties in de tandvertanding wordt geminimaliseerd. Daarnaast helpen effectieve koelmechanismen de tijdens de werking gegenereerde warmte af te voeren, waardoor overmatige temperatuurstijging die de tandwielvertanding zou kunnen beïnvloeden, wordt voorkomen.
- Robuuste constructie:
Planetaire tandwieloverbrengingen worden doorgaans vervaardigd met behulp van zeer sterke materialen en nauwkeurige productietechnieken. Deze robuuste constructie verbetert het vermogen van het tandwielsysteem om variaties in de tandvertanding te weerstaan. Door te zorgen voor hoogwaardige tandwielcomponenten, een juiste warmtebehandeling en strenge kwaliteitscontroles, zijn planetaire tandwieloverbrengingen gebouwd om de dynamische belastingen en variaties tijdens gebruik aan te kunnen.
Samenvattend kunnen planetaire tandwieloverbrengingen variaties in tandcontact opvangen door hun tolerantie voor uitlijningsfouten, de lastverdeling over meerdere planeetwielen, flexibele montage en ondersteuning, effectieve smering en koeling, en een robuuste constructie. Deze ontwerpoverwegingen en -eigenschappen zorgen ervoor dat planetaire tandwieloverbrengingen een goed tandcontact behouden, slijtage en geluid minimaliseren en betrouwbare prestaties garanderen in diverse toepassingen, waaronder autotransmissies, industriële machines en aandrijfsystemen.
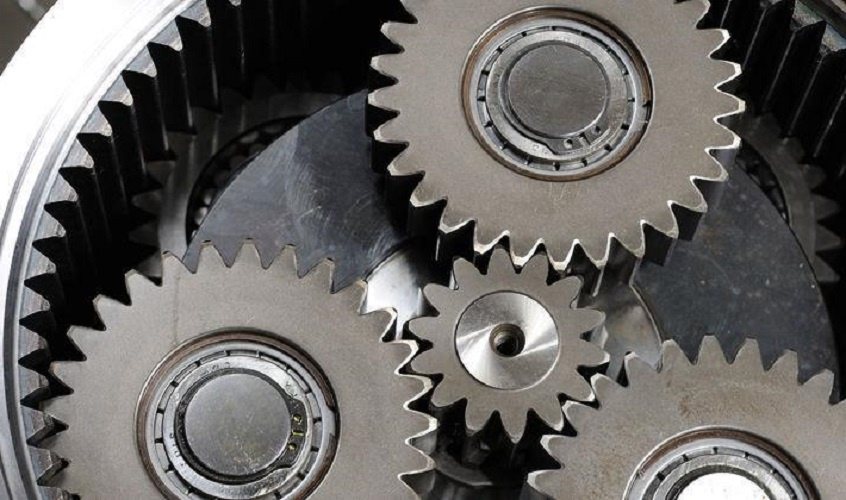
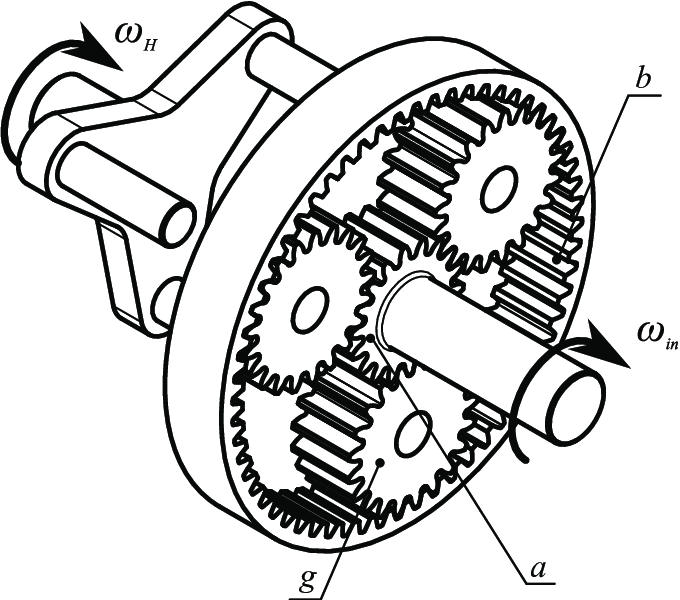
Can you describe the role of sun gears, planet gears, and ring gears in planetary systems?
In a planetary gear system, each component—the sun gear, planet gears, and ring gear—plays a crucial role in the overall operation and functionality. Let’s explore the roles of these gears:
- Sun Gear:
The sun gear is a central component in a planetary gear system. It is typically located at the center and is driven by an input source such as a motor or engine. The sun gear receives the input power and transmits it to the other gears in the system. As the sun gear rotates, it drives the rotation of the planet gears, which, in turn, contribute to the overall gear operation. The size and number of teeth on the sun gear determine the gear ratio and torque characteristics of the system.
- Planet Gears:
The planet gears are gears that surround the sun gear in a planetary gear system. They are typically smaller in size compared to the sun gear and are connected to a carrier or arm. The planet gears mesh with both the sun gear and the ring gear. As the sun gear rotates, it drives the rotation of the planet gears. The planet gears exhibit both rotational and orbital motion. While they rotate on their own axes, they also orbit around the sun gear. This combination of rotational and orbital movement allows the planet gears to transmit torque and contribute to the overall gear reduction or amplification. The arrangement and number of planet gears can vary depending on the specific design and requirements of the system.
- Ring Gear:
The ring gear is the outermost gear in a planetary gear system. It has internal teeth that mesh with the planet gears. The ring gear remains fixed or stationary while the sun gear and planet gears rotate. The interaction between the planet gears and the ring gear enables the gear system to achieve gear reduction or amplification. The size and number of teeth on the ring gear also influence the gear ratio and torque characteristics of the system.
In summary, the sun gear serves as the primary driver, receiving the input power and transmitting it to the other gears. The planet gears rotate and orbit around the sun gear, contributing to torque transmission and gear functionality. The ring gear remains fixed and meshes with the planet gears, allowing for gear reduction or amplification. Together, these gears work in harmony to achieve the desired gear ratios, torque transmission, and overall operation of planetary gear systems.
editor by CX 2023-11-02