Produktbeschreibung
60mm DC SERVO MOTOR WITH BRAKE
Specification:
| General Specification | |
| (Item) | (Specification) |
| Winding type | Star |
| Hall effect angle | 120 120 degree electrical angle |
| Shaft run out | 0.571mm |
| Radial play | 0.02mm@450g |
| End play | 0.08mm@450g |
| Max.radial force | 115N @20mm form the flange |
| Max.axial force | 45N |
| Insulation class | Class B |
| Dielectric strength | 500VDC for 1 minute |
| Insulation resistance | 100MΩ Min.,500VDC |
| Electrical Specification | |||||
| Specification | Einheit | JK60BLS01 | JK60BLS02 | JK60BLS03 | JK60BLS04 |
| Number Of Phase | Phase | 3 | |||
| Number Of Poles | Poles | 8 | |||
| Rated Voltage | VDC | 48 | |||
| Rated Speed | Rpm | 3000 | |||
| Rated Torque | N.m | 0.3 | 0.6 | 0.9 | 1.2 |
| Rated Current | Amps | 2.8 | 5.2 | 7.5 | 9.5 |
| Rated Power | W | 94 | 188 | 283 | 377 |
| Peak Torque | N.m | 0.9 | 1.8 | 2.7 | 3.6 |
| Peak Current | Amps | 8.4 | 15.6 | 22.5 | 28.5 |
| Back E.M.F | V/Krpm | 12.1 | 12.6 | 12.4 | 13.3 |
| Torque Constant | N.m/A | 0.116 | 0.12 | 0.118 | 0.127 |
| Rotor Inertia | Kg.c | 0.24 | 0.48 | 0.72 | 0.96 |
| Body Length | mm | 78 | 99 | 120 | 141 |
| Weight | Kg | 0.85 | 1.25 | 1.65 | 2.05 |
| Sensor | /Honeywell | ||||
| Insulation Class | B | ||||
| Degree of Protection | IP30 | ||||
| Storage Temperature | -25~+70ºC | ||||
| Operating Temperature | -15~+50ºC | ||||
| Working Humidity | 85% RH | ||||
Drawing:
Company Profile:
HangZhou CHINAMFG CO.,LTD (HangZhou Jingkong Motor&Electric Appliance Co.,Ltd)is an ISO9001 Professional
manufacturer. Was established in 2011 year. We are a professional manufacturer in HangZhou city, China. Production Capacity
exceeds more than 1million motors per year.
Our Company offers 3 major series of products: Hybrid Stepper motors, Brushless Dc motor and Dc Brush motor.
We are always continues develop new type models.We are also have several joint venture companies who specialized in the
production of AC servo motor, PM stepper motors, Spindlemotor and Motor drivers. We export our motors to more than 30
countries Such as United States, Germany, Russia, Turkey, Brazil and so on.
Jkongmotor sold to major manufacturing Companies for Industry of automation, medical and health care equipment,
3d printermachines, packing devices, Information Technology, household appliance products. We have an Engineering team
with many years of experience in application Engineering, design Engineering with the latest advances equipment. Our
Engineering Staff provides the finest quality product with service after the product is delivered to our Customers.
| Anwendung: | Universal, Industrial, Household Appliances, Car, Power Tools |
|---|---|
| Operating Speed: | High Speed |
| Function: | Control |
| Casing Protection: | Closed Type |
| Number of Poles: | 8 |
| Structure and Working Principle: | Brushless |
| Proben: |
US$ 28.5/Piece
1 Stück (Mindestbestellmenge) | |
|---|
| Anpassung: |
Verfügbar
| Kundenspezifische Anfrage |
|---|
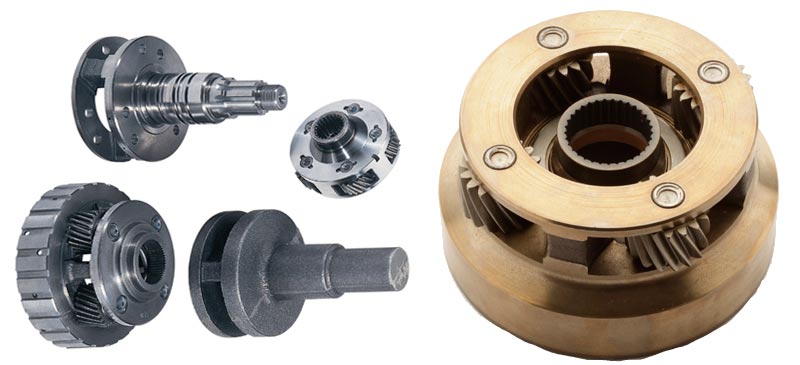
How do you calculate the gear ratio involving sun, planet, and ring gears?
The gear ratio in a planetary gear system can be calculated by considering the number of teeth on the sun gear, planet gears, and ring gear. The gear ratio determines the relationship between the input speed and the output speed of the system. Here’s how you can calculate the gear ratio:
- Step 1: Count the Teeth:
Count the number of teeth on the sun gear (S), the planet gears (P), and the ring gear (R). These numbers represent the respective gear’s tooth count.
- Step 2: Determine the Gear Arrangement:
Identify the gear arrangement. In a simple planetary gear system, the sun gear is at the center, surrounded by planet gears, and enclosed by the ring gear.
- Step 3: Calculate the Gear Ratio:
The gear ratio (GR) can be determined using the formula:
GR = (R + P) / S
Where:
- R represents the number of teeth on the ring gear
- P represents the number of teeth on the planet gears (assuming they have the same number of teeth)
- S represents the number of teeth on the sun gear
The resulting gear ratio represents the speed relationship between the input and output of the planetary gear system. A gear ratio greater than 1 indicates a speed reduction, while a gear ratio less than 1 indicates a speed increase.
It’s important to note that in more complex planetary gear systems, where there are multiple sets of planet gears or additional gears, the calculation of the gear ratio may involve considering multiple gear stages and their respective tooth counts.
In summary, to calculate the gear ratio involving sun, planet, and ring gears, you need to count the teeth on each gear and use the formula (R + P) / S, where R is the number of teeth on the ring gear, P is the number of teeth on the planet gears, and S is the number of teeth on the sun gear. This calculation provides the gear ratio that defines the speed relationship between the input and output of the planetary gear system.
Wie gleichen Planetengetriebe Schwankungen im Zahneingriff während des Betriebs aus?
Planetengetriebe sind so konstruiert, dass sie Schwankungen im Zahneingriff während des Betriebs ausgleichen und so einen reibungslosen und zuverlässigen Lauf gewährleisten. Schauen wir uns an, wie Planetengetriebe diese Schwankungen kompensieren:
- Toleranz gegenüber Fehlausrichtung:
Planetengetriebe sind so konstruiert, dass sie eine gewisse Toleranz gegenüber Fluchtungsfehlern aufweisen. Das bedeutet, dass geringfügige Abweichungen im Zahneingriff aufgrund von Fertigungstoleranzen, Montage oder Betriebsbedingungen ausgeglichen werden können, ohne die Funktion des Getriebes wesentlich zu beeinträchtigen. Die Zahnflanken sind sorgfältig mit geeigneten Profilen, Toleranzen und Zahnflankenspielen ausgelegt, um einen gewissen Grad an Fluchtungsfehlern zu ermöglichen und gleichzeitig die einwandfreie Funktion zu gewährleisten.
- Lastverteilung:
Die Anordnung mehrerer Planetenräder in einem Planetengetriebe verteilt die Last gleichmäßig auf mehrere Zähne. Jedes Planetenrad teilt die Last mit den benachbarten Rädern, wodurch die Belastung einzelner Zähne reduziert und ein gleichmäßiger Zahneingriff gefördert wird. Diese Lastverteilung minimiert lokalen Verschleiß, Geräusche und Vibrationen und sorgt so für einen ruhigeren und effizienteren Betrieb.
- Flexible Montage und Unterstützung:
Planetengetriebe werden häufig auf flexiblen Trägerstrukturen wie Lagern oder flexiblen Kupplungen montiert. Diese Komponenten helfen, geringfügige Abweichungen im Zahneingriff während des Betriebs auszugleichen. Die flexiblen Montage- und Trägersysteme bieten ein gewisses Maß an Nachgiebigkeit und ermöglichen es den Zahnrädern, sich selbst einzustellen und unter verschiedenen Betriebsbedingungen einen korrekten Zahneingriff aufrechtzuerhalten.
- Schmierung und Kühlung:
Eine adäquate Schmierung und Kühlung sind entscheidend für den Ausgleich von Eingriffsabweichungen. Schmierstoffe reduzieren Reibung und Verschleiß zwischen den Zahnrädern, gewährleisten einen reibungslosen Lauf und minimieren die Auswirkungen von Eingriffsabweichungen. Effektive Kühlmechanismen tragen zudem zur Wärmeabfuhr bei und verhindern einen übermäßigen Temperaturanstieg, der die Verzahnungsleistung beeinträchtigen könnte.
- Robuste Konstruktion:
Planetengetriebe werden typischerweise aus hochfesten Werkstoffen und mit präzisen Fertigungstechniken hergestellt. Diese robuste Konstruktion verbessert die Fähigkeit des Getriebesystems, Schwankungen im Zahneingriff standzuhalten. Durch die Verwendung hochwertiger Getriebekomponenten, eine sachgemäße Wärmebehandlung und eine strenge Qualitätskontrolle sind Planetengetriebe so konstruiert, dass sie den dynamischen Belastungen und Schwankungen im Betrieb gewachsen sind.
Zusammenfassend lässt sich sagen, dass Planetengetriebe Abweichungen im Zahneingriff durch ihre Toleranz gegenüber Fluchtungsfehlern, die Lastverteilung auf mehrere Planetenräder, die flexible Montage und Lagerung, die effektive Schmierung und Kühlung sowie ihre robuste Bauweise ausgleichen. Diese Konstruktionsmerkmale ermöglichen es Planetengetrieben, einen optimalen Zahneingriff aufrechtzuerhalten, Verschleiß und Geräusche zu minimieren und in verschiedenen Anwendungen, wie z. B. in Automobilgetrieben, Industriemaschinen und Kraftübertragungssystemen, zuverlässig zu funktionieren.
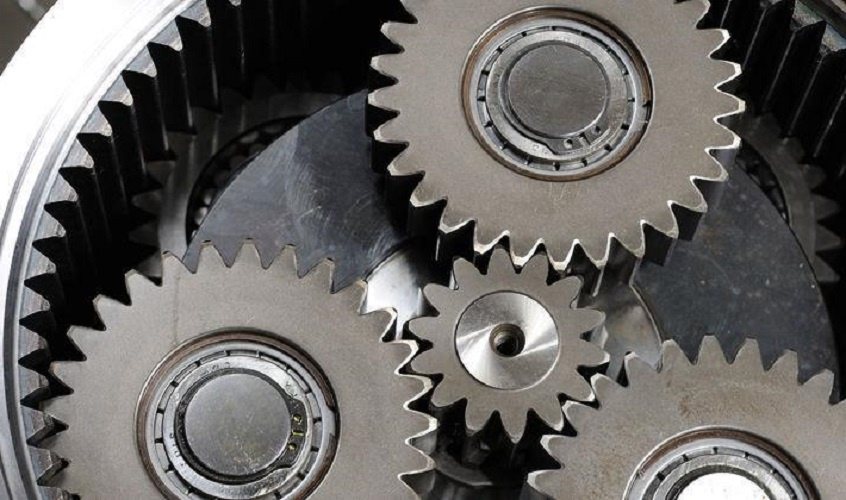
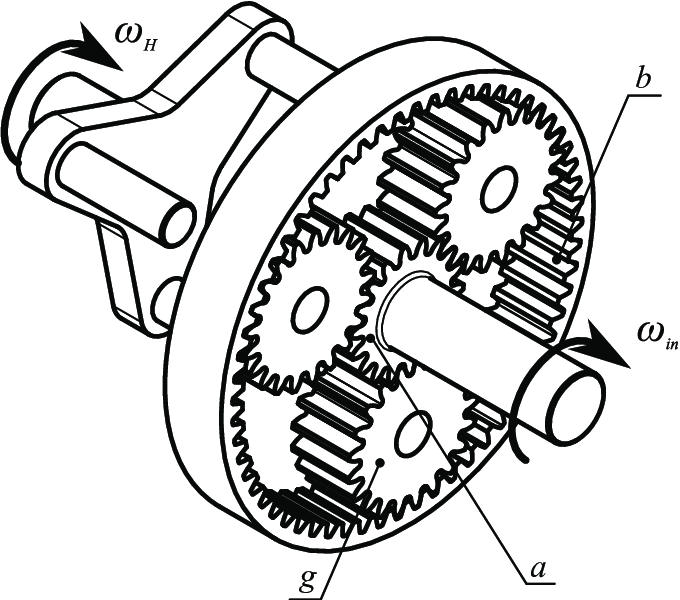
Can you describe the role of sun gears, planet gears, and ring gears in planetary systems?
In a planetary gear system, each component—the sun gear, planet gears, and ring gear—plays a crucial role in the overall operation and functionality. Let’s explore the roles of these gears:
- Sun Gear:
The sun gear is a central component in a planetary gear system. It is typically located at the center and is driven by an input source such as a motor or engine. The sun gear receives the input power and transmits it to the other gears in the system. As the sun gear rotates, it drives the rotation of the planet gears, which, in turn, contribute to the overall gear operation. The size and number of teeth on the sun gear determine the gear ratio and torque characteristics of the system.
- Planet Gears:
The planet gears are gears that surround the sun gear in a planetary gear system. They are typically smaller in size compared to the sun gear and are connected to a carrier or arm. The planet gears mesh with both the sun gear and the ring gear. As the sun gear rotates, it drives the rotation of the planet gears. The planet gears exhibit both rotational and orbital motion. While they rotate on their own axes, they also orbit around the sun gear. This combination of rotational and orbital movement allows the planet gears to transmit torque and contribute to the overall gear reduction or amplification. The arrangement and number of planet gears can vary depending on the specific design and requirements of the system.
- Ring Gear:
The ring gear is the outermost gear in a planetary gear system. It has internal teeth that mesh with the planet gears. The ring gear remains fixed or stationary while the sun gear and planet gears rotate. The interaction between the planet gears and the ring gear enables the gear system to achieve gear reduction or amplification. The size and number of teeth on the ring gear also influence the gear ratio and torque characteristics of the system.
In summary, the sun gear serves as the primary driver, receiving the input power and transmitting it to the other gears. The planet gears rotate and orbit around the sun gear, contributing to torque transmission and gear functionality. The ring gear remains fixed and meshes with the planet gears, allowing for gear reduction or amplification. Together, these gears work in harmony to achieve the desired gear ratios, torque transmission, and overall operation of planetary gear systems.
editor by CX 2023-11-02